
Selecting the Right Drive Wheel for AGV and AMR Task Profiles
Selecting the Right Drive Wheel for AGV and AMR Task Profiles
An industry reference for matching drive wheel configuration, torque and load rating to specific AGV and AMR duty profiles.
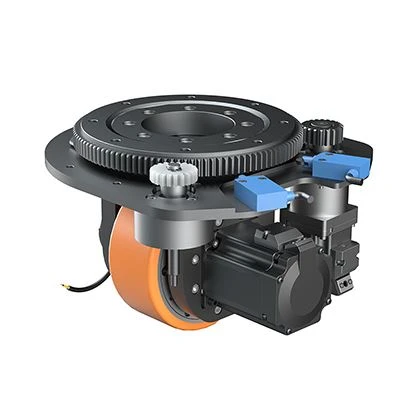
A drive wheel unit is the mechanical interface between a mobile robot motor and the floor it operates on. It carries a defined share of vehicle weight, converts motor output into traction, and in differential or steered designs establishes how the vehicle turns and how precisely it can position itself. In practical terms, the drive wheel is one of the few components in an AGV or AMR that simultaneously constrains payload, navigation behaviour and chassis architecture.
Because mobile robots are not one product category, no single drive wheel specification serves them all. Vehicles operating in warehouse logistics, automotive assembly, electronics manufacturing, food and beverage production, pharmaceutical production, e-commerce fulfilment and airport or port logistics work under different loads, duty cycles, floor conditions and maneuverability requirements. Third-party estimates place the global AGV wheel drive market at approximately USD 1.2 billion in 2024, projected to reach USD 3.5 billion by 2034 (Reports and Data), while the industrial logistics segment of the AGV market is projected to grow at a CAGR of 11.6% (MarketsandMarkets). That growth is distributed across several distinct vehicle classes, each with its own duty profile rather than a shared specification.
This reference sets out a task-profile method for selecting a drive wheel and uses two Plutools units to mark the ends of the common range: the PLT-120 differential drive wheel, rated at 150 kg drive wheel load with a PU tread, and the PLT-198 planetary horizontal drive wheel with steering, rated at 1500 kg maximum load and 576 Nm maximum torque. Shanghai Plutools Automation Corporation Co., Ltd. is a Shanghai-based manufacturer of AGV drive wheels and motion control assemblies, founded in 2017 and operating a 10,000 m² production facility.
Why the Task Profile Should Be Defined Before the Wheel Is Chosen
Drive wheel mismatches rarely surface at the drawing stage. They appear in service: a vehicle that tracks accurately when empty loses traction once a full pallet is added on a ramp; a chassis specified around a mid-size unit runs out of mounting envelope when the payload target doubles; a unit that steers cleanly at low speed exceeds the battery budget at the acceleration the process actually demands. In each case the wheel was treated as a product category rather than matched to a measured duty profile.
A task profile is the set of operating parameters the vehicle must satisfy in normal, repeated service. For drive wheel selection, five variables do most of the work.
| Variable | What to quantify | Why it changes the wheel |
|---|---|---|
| Payload and per-wheel load | Gross vehicle weight plus payload, number of drive wheels, static and dynamic load transfer during braking and cornering | Sets the required load rating per unit. PLT-120 is rated at 150 kg drive wheel load; PLT-198 at 1500 kg maximum load. |
| Duty cycle and braking | Starts and stops per hour, acceleration target, braking frequency, continuous or intermittent operation | Sets the torque requirement and whether rated output torque or maximum acceleration and braking torque is the binding figure. |
| Maneuverability and navigation | Turning radius, aisle width, in-place rotation, forward and reverse travel, need for a steering axis | Decides between differential, steered and multi-wheel coordinated drive modes. |
| Floor and environment | Concrete, epoxy, steel or slightly uneven floors, temperature, humidity, dust, cleanroom or explosion-proof zones | Decides tread compound, protection level and whether a special version is required. |
| Mounting envelope and service access | Available vertical and horizontal space, mounting dimensions, cabling, encoder and brake placement | Decides vertical or horizontal orientation and whether steering can be integrated into the unit. |
A profile that omits any of these five variables produces a wheel that is either oversized, adding cost, mass and current draw, or undersized, which shows up as traction loss, positioning error or accelerated wear.
Two Reference Points: 150 kg Precision and 1500 kg Torque
Light, precise platforms: the PLT-120 differential drive wheel
| Model | PLT-120 |
| Product name | Differential Drive Wheel |
| Rated power / voltage / current | 400 W / 48 V / 11.2 A |
| Rated speed | 3000 rpm |
| Rated torque | 1.28 Nm |
| Transmission ratio | 9, 20 I |
| Rated output torque | 10, 21 Nm |
| Maximum acceleration and braking torque | 20, 42 Nm |
| Drive wheel load | 150 kg |
| Total weight of drive wheel | 5 ± 2 kg |
| IP protection level | IP65 |
| Tread and body material | PU tread, carbon steel |
A 400 W motor at 48 V and a 150 kg drive wheel load rating place the PLT-120 at the light end of the range. Two transmission ratio options, 9 and 20, let a project trade top speed for tractive effort without changing the unit envelope: rated output torque is 10 Nm at the lower ratio and 21 Nm at the higher ratio, with maximum acceleration and braking torque of 20 Nm and 42 Nm. The unit weighs 5 ± 2 kg and carries IP65 protection, which matters for AMRs working in dusty or wash-adjacent areas. A PU tread keeps running noise low and protects finished floors, consistent with the wider use of polyurethane in indoor industrial wheel applications (Mordor Intelligence).
Heavy material handling: the PLT-198 planetary horizontal drive wheel with steering
| Model | PLT-198 |
| Product name | Horizontal Drive Wheel |
| Type | Planetary horizontal drive wheel with steering |
| Power / rated voltage / rated current | 3000 W / 48 V / 68 A |
| Speed | 3000 rpm |
| Rated torque | 9.55 Nm |
| Reduction ratio | 32 |
| Output torque / max torque | 260 Nm / 576 Nm |
| Max load | 1500 kg |
| Tread and body material | PU tread, carbon steel |
The PLT-198 pairs a 3000 W, 48 V motor with a reduction ratio of 32, producing 260 Nm output torque and 576 Nm maximum torque against a 1500 kg maximum load. The structural difference is as decisive as the numbers: this is a planetary horizontal unit with an integrated steering function, so path control is achieved through the drive wheel itself rather than through a separate steering assembly mounted elsewhere on the chassis.
These two units are not interchangeable and are not intended to be. A 150 kg-rated differential wheel cannot carry a 1500 kg deck, and a 1500 kg steered unit is excessive for a small shelf-transport AMR, where the additional mass, steering axis and current draw would reduce efficiency without improving the task outcome. The selection question is therefore never which unit is better in general, but which unit matches the profile.
How to Read Torque, Load and Speed on a Drive Wheel Datasheet
Three torque figures appear on AGV drive wheel datasheets, and confusing them is a common source of over- or under-specification. Rated torque is measured at the motor shaft. Output torque is the figure after the gearbox multiplies motor torque through the reduction ratio, and it is the number that describes steady tractive capability. Maximum torque is a short-duration figure used for acceleration and braking events rather than continuous duty.
The gap between these figures is set by the reduction ratio. The PLT-198 converts a 9.55 Nm rated motor torque into 260 Nm output torque through a ratio of 32, with 576 Nm available at maximum. The PLT-120, at ratios of 9 and 20, produces 10 Nm or 21 Nm output torque from a 1.28 Nm rated motor torque, with 20 Nm and 42 Nm of maximum acceleration and braking torque.
Load ratings follow the same logic. A stated load figure applies to the unit, not to the vehicle. A four-wheel chassis using two PLT-120 differential units distributes vehicle and payload weight across both drive wheels as well as any castor or support wheels, so the 150 kg figure is a per-unit ceiling to design against rather than a vehicle payload rating. The same applies to the 1500 kg maximum load figure of the PLT-198, which also carries the weight transfer that occurs during braking and cornering.
Speed and voltage complete the picture. Rated speed of 3000 rpm appears across both reference units, but a 24 V platform requires a different unit family: the PLT-230 vertical drive wheel operates at 24 V with 1500 W and a 1500 kg maximum load, which suits vehicles whose battery architecture is fixed at that voltage.
Structural Configuration Has to Support Both Maneuverability and Load
Orientation and steering integration are not cosmetic choices. A vertical drive wheel places the motor and gearbox above the wheel axis, which suits chassis with height available and a need for a compact floor footprint. A horizontal drive wheel lays the axis parallel to the floor, which suits low-deck vehicles such as transfer carts and tow tractors. Adding a steering function integrates the steering axis into the unit itself, while a differential pair achieves turning through speed difference between two wheels rather than through a steering actuator.
Dual differential drive wheels allow a zero-turn radius and are widely used in smaller logistics robots (Mobile Robot Guide). Steering units are used where the vehicle must hold a path while carrying a heavier deck, and where a steering angle is part of the navigation strategy rather than an outcome of wheel speed control.
| Model | Product name | Configuration | Max load | Motor power / voltage |
|---|---|---|---|---|
| PLT-120 | Differential Drive Wheel | Differential | 150 kg | 400 W / 48 V |
| PLT-167 | AGV Drive Wheel Unit | Horizontal, without steering | 800 kg | 750 W / 48 V |
| PLT-220 | Parallel Horizontal Drive Wheel | Parallel horizontal, with steering | 1000 kg | 750 W / 48 V |
| PLT-210 | Forklift Drive Wheel | Parallel horizontal, with steering | 1200 kg | 3000 W / 48 V |
| PLT-198 | Horizontal Drive Wheel | Planetary horizontal, with steering | 1500 kg | 3000 W / 48 V |
| PLT-150 | Vertical Drive Wheel | Vertical, with steering | 500 kg | 750 W / 48 V |
| PLT-230P | Robot Drive Wheel | Vertical, with shock absorption, IP65 | 1200 kg | 2500 W servo / 48 V |
| PLT-230 | AGV Drive Wheel | Vertical, without steering | 1500 kg | 1500 W / 24 V |
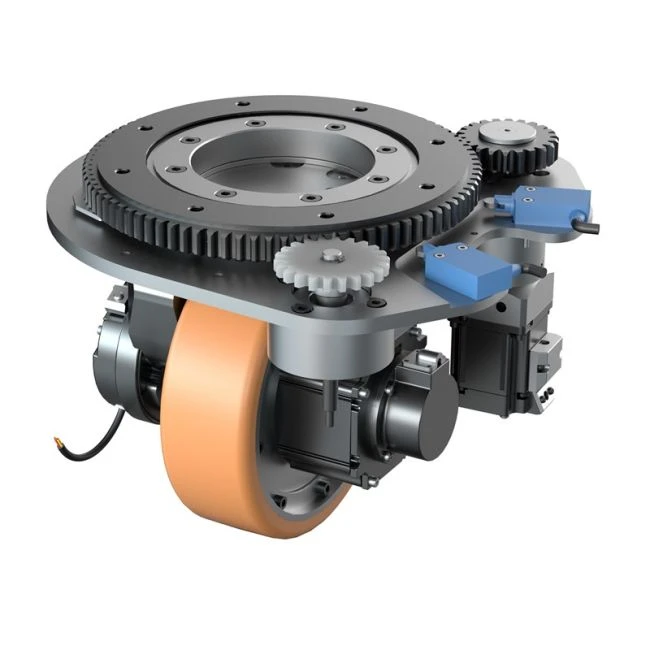
The configuration decision also has a boundary worth stating plainly. An integrated unit fixes certain interfaces: mounting dimensions, wheel diameter and reduction ratio belong to the model, so when a platform payload target changes materially, moving to a higher-rated unit usually means changing the chassis envelope rather than swapping one component for another. Steering integration removes a separate actuator from the design but adds a controlled axis that must be planned for from the first frame drawing.
Where an existing platform cannot be re-dimensioned, customization is the practical route. Plutools accepts customization across load capacity, wheel diameter, motor power, voltage, rated speed, reduction ratio, mounting dimensions, encoder type, brake system, connector, cable length, logo and packaging. That flexibility follows a development and production cycle rather than an off-the-shelf substitution, which is a real constraint for short prototype windows.
Matching Task Profiles to Drive Wheel Configurations
The table below converts the profile variables into configuration choices for common automation scenarios. It is a starting point for specification discussion, not a substitute for load calculation on the specific chassis.
| Task profile | Typical vehicle | Fitting configuration | Reference unit |
|---|---|---|---|
| Light payload, narrow aisles, high navigation precision | Shelf-transport AMR, small logistics robot | Dual differential, compact, IP65 | PLT-120 (150 kg, 400 W) |
| Mid payload with steered path following | Assembly-line transfer, pallet mover | Parallel horizontal with steering | PLT-220 (1000 kg, 58 Nm output) |
| High-torque material handling with steering | Heavy AGV, automated forklift | Planetary or parallel horizontal with steering | PLT-198 (1500 kg, 576 Nm max), PLT-210 (1200 kg, 576 Nm max) |
| Low-deck transfer without steering | Tow tractor, conveyor-linked transfer cart | Horizontal without steering | PLT-167 (800 kg, 120 Nm max) |
| Height-constrained chassis with steering | Compact AGV, low-clearance platform | Vertical with steering | PLT-150 (500 kg, 114 Nm max) |
| Heavy AMR on slightly uneven industrial floor | Heavy-duty AMR with servo control | Vertical with shock absorption, IP65 | PLT-230P (1200 kg, servo, 2500 W) |
| 24 V battery architecture | Heavy AGV with fixed low-voltage platform | Vertical without steering | PLT-230 (1500 kg, 300 Nm max, 24 V) |
Two patterns are worth noting. First, load and torque do not scale together by default: the PLT-220 and PLT-198 both use steered horizontal configurations, but output torque differs substantially because the reduction ratio and motor power differ. Second, the environment can override a load-based choice, which is why the same vehicle class can require different wheel variants across sites.
The application scope of these units covers intelligent logistics, industrial automation, warehousing, automotive manufacturing, electronics manufacturing, food and beverage production, pharmaceutical manufacturing, e-commerce fulfilment centres, airport logistics and port transportation. Typical use cases include AGV and AMR development, automated forklift manufacturing, assembly-line delivery, pallet transport, warehouse picking and finished-goods handling, both in new automation projects and in upgrades of existing logistics equipment.
Market Trends Reshaping AGV and AMR Task Profiles
Several converging trends are pushing task profiles apart rather than toward a single specification. The global AGV wheel drive market was valued at roughly USD 1.2 billion in 2024 and is projected to reach USD 3.5 billion by 2034, with a CAGR of 11.5% from 2024 to 2034 driven by logistics and warehouse automation (Reports and Data). Growth of that scale implies a widening installed base of vehicles at different load classes, not a consolidation around one drive wheel size.
Regional demand is concentrated. Asia Pacific accounted for a 37.6% revenue share of the global AGV market in 2025 (Grand View Research), and the China mobile robot market reached a scale of 22.1 billion yuan in 2024 with more than 139,000 units sold (CMRA). China has also increased its export volume of mobile robots, with suppliers targeting Southeast Asia and Europe (China Mobile Robot Alliance). For component buyers, this means more regional sourcing options and more supplier comparison work rather than less.
The vehicle mix itself is shifting toward electric and automated drive systems. Electric forklifts now command over 70% market share in many regions as a replacement for combustion models (MarketsandMarkets), and lithium-ion battery technology powers the majority of new AGV and AMR drive units, reducing downtime concerns (Fortune Business Insights). Both trends place more weight on drive wheel efficiency, braking behaviour and duty-cycle matching, since an electric platform has to account for every watt of continuous current draw.
At the component level, integrated steering drive modules are replacing discrete components to reduce manufacturer assembly time and maintenance complexity (Brandessence Research), while mecanum and omnidirectional drive systems are increasingly used for AMRs in high-density warehouses (Interact Analysis). For buyers, integrated steering units reduce assembly steps but shift the specification burden earlier: the steering geometry, reduction ratio and mounting envelope must be settled while the chassis is still on the drawing board.
Integrated Drive Units vs Discrete Component Assemblies
| Criterion | Discrete motor, gearbox and wheel | Integrated drive wheel unit |
|---|---|---|
| Assembly steps at the chassis line | Higher, with separate alignment and coupling | Lower, with one mounting interface |
| Occupied volume | Larger, requires routed drive train | Compact, designed for AGV and AMR integration |
| Motion accuracy | Dependent on assembly alignment and coupling quality | Set by the unit, with encoder and brake integration |
| Change cost when payload grows | Component-level substitution possible | Usually requires chassis envelope change or custom dimensions |
| Service strategy | Individual part replacement | Unit-level replacement planning |
| Ratings | Must be combined and validated by the integrator | Published per unit, for example 150 kg on PLT-120 or 1500 kg on PLT-198 |
The honest limitation of integrated units is flexibility cost. Because the drive, gearbox, bearing set, encoder, brake and, in steered models, the steering axis are engineered as one assembly, field service is normally planned as unit replacement rather than part-level repair. Teams with depot-level rebuild capability and large fleets may value component-level maintainability more than assembly time savings.
A second boundary concerns load figures. A rated load is a defined maximum under the conditions the unit was designed and tested for, not a guarantee at any duty cycle. Continuous operation at the maximum acceleration and braking torque, a floor with different friction characteristics, or a different weight distribution on a four-wheel chassis all change the effective demand on the wheel. Nor is PU tread a universal answer: while it offers low noise and floor protection indoors, special versions are required for low-temperature warehouses, high-humidity areas, cleanrooms, dusty workshops, anti-static or oil-resistant environments, and explosion-proof applications. Those must be specified at the project stage rather than assumed.
Compliance is part of the same picture. Steering and braking systems are explicitly covered by ISO 3691-4:2023, the primary international safety standard for driverless industrial trucks, and EN 1175:2020 sets electrical and electronic safety requirements for industrial trucks, with ANSI/ITSDF B56.5 governing driverless industrial vehicles in the United States. Because these standards address the functions a drive wheel performs, the safety documentation a supplier can provide is a practical selection input, not paperwork to be collected after the specification is frozen.
What to Verify Before Committing to a Drive Wheel
Procurement teams evaluating AGV drive wheels can reduce later rework by confirming a defined set of items against the task profile rather than against catalogue position.
- Load and torque context: confirm whether the stated load is per unit and whether the quoted torque is rated output torque or short-duration maximum torque.
- Configuration fit: verify that vertical or horizontal orientation, differential or steered operation, and steering integration match the chassis plan and the required turning geometry.
- Environment: confirm the protection level and whether a special version is needed for temperature, humidity, dust, cleanroom, static or explosion-proof conditions.
- Interfaces: mounting dimensions, encoder type, brake system, connector and cable length should be agreed as part of the specification.
- Quality evidence: Plutools states 100% test on production units, which is the kind of claim that should be supported with the corresponding test record.
- Supply parameters: MOQ of 2 units, lead time of 30 to 45 days and monthly capacity of 12,000 units define the practical rhythm of a program.
- Support model: after-sales support is provided as remote technical support, which should be matched to the integrator own service capability.
Track record can also be checked against comparable programs. Plutools supplied 200 drive wheel units to an AGV manufacturer and industrial automation system integrator in Brazil for an ultra-heavy-duty AGV with multiple navigation modes, using the units for drive, differential steering and precise motion control. Over a two-year period the reported results were stable operation under heavy-load conditions, accurate route tracking, flexible steering and reliable material transportation, with high load capacity, high output torque and multiple navigation compatibility identified as the deciding factors.
Future Outlook
As automation moves into more specialised environments, task profiles are likely to fragment further rather than converge. Growth in industrial logistics, combined with the shift toward electric and automated drive systems, will keep demand spread across several load classes. At the same time, omnidirectional and mecanum configurations are expanding the manoeuvrability options available in high-density warehouses, which changes the maneuverability variable in the task profile rather than removing it.
For buyers, the practical implication is that drive wheel selection should stay tied to the specific duty profile rather than to a single preferred model or to a category label such as heavy duty. A defined profile, verified ratings, and agreement on configuration and interfaces before the chassis design is frozen will continue to be the most reliable way to avoid rework later in a mobile robot program.
Frequently Asked Questions
What is a task profile in AGV and AMR drive wheel selection?
A task profile is the set of operating parameters a vehicle must meet in normal repeated service: payload and per-wheel load, duty cycle and braking frequency, maneuverability and navigation requirements, floor and environmental conditions, and available mounting envelope. In drive wheel selection the profile determines the required load rating, the torque figure that governs design, the configuration type and any special version needed. A profile is specific to a vehicle and its route, which is why two fleets in the same building can require different drive wheel models.
How do I choose between a differential and a steering drive wheel?
The decision follows the maneuverability and load requirements of the chassis. Dual differential drive wheels allow a zero-turn radius and are widely used in smaller logistics robots, because turning is achieved through speed difference rather than through a steering actuator. Steered units, such as the PLT-198 planetary horizontal drive wheel with steering or the PLT-220 parallel horizontal drive wheel with steering, integrate a steering axis into the unit and are used where a heavier deck must follow a defined path. Load rating, torque and mounting space should be confirmed for either choice.
How should load and torque figures on a datasheet be interpreted?
Load figures apply per drive wheel unit, not to the whole vehicle, so they must be compared against the load each wheel actually carries, including weight transfer during braking and cornering. Torque figures also differ in meaning: rated torque is measured at the motor shaft, output torque is the value after gear reduction and describes steady tractive capability, and maximum torque is a short-duration figure for acceleration and braking. For the PLT-198, a 9.55 Nm rated motor torque becomes 260 Nm output torque through a ratio of 32, with 576 Nm available at maximum.
Can one drive wheel model serve both a light AMR and a heavy AGV?
Generally no, because the two task profiles pull the specification in opposite directions. A light AMR benefits from a compact, low-mass unit such as the PLT-120, rated at 150 kg drive wheel load with IP65 protection, where low noise and floor protection matter more than torque. A heavy material-handling AGV requires ratings such as the 1500 kg maximum load and 576 Nm maximum torque of the PLT-198. Using an oversized unit on a light platform adds mass and current draw, while an undersized unit on a heavy platform produces traction loss and positioning error.
Which operating environment factors change drive wheel selection?
Floor type and condition, temperature, humidity, dust, static control, oil exposure and the presence of cleanroom or explosion-proof requirements all affect selection. Indoors, PU tread is commonly used for low noise and floor protection, and polyurethane is widely adopted in forklift and indoor industrial wheel applications. However, PU is not a universal answer: low-temperature warehouses, high-humidity areas, cleanrooms, dusty workshops, anti-static and oil-resistant environments, and explosion-proof zones require special versions specified at the project stage rather than standard units.
How is a drive wheel customized for a specific AGV or AMR platform?
Customization typically covers load capacity, wheel diameter, motor power, voltage, rated speed, reduction ratio, mounting dimensions, encoder type, brake system, connector, cable length, logo and packaging. For AGV and AMR builders this allows a unit to match an existing chassis envelope and control architecture where an off-the-shelf model does not fit. The trade-off is timing: custom work follows a development and production cycle, and MOQ, lead time and production capacity need to be planned into the project schedule accordingly.
For readers who want the full model range and specification tables, the Plutools selection handbook is available at PLT selection handbook 2026.